To overcome these engineering and intelligent robotics design hurdles, manufacturers integrate Interface’s load cells, multi-axis sensors, and torque transducers directly into robotic architectures, enabling real-time physical feedback and control via wireless telemetry and digital instrumentation.
Roboforming
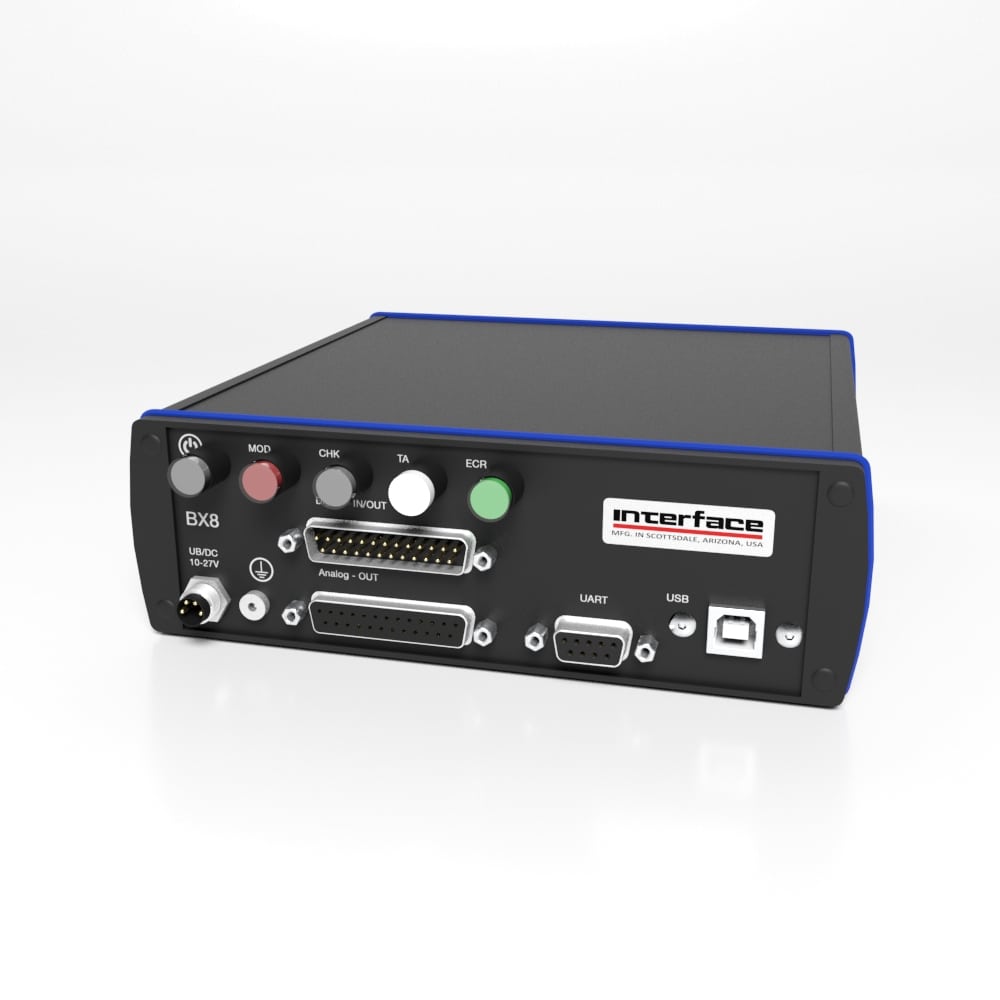
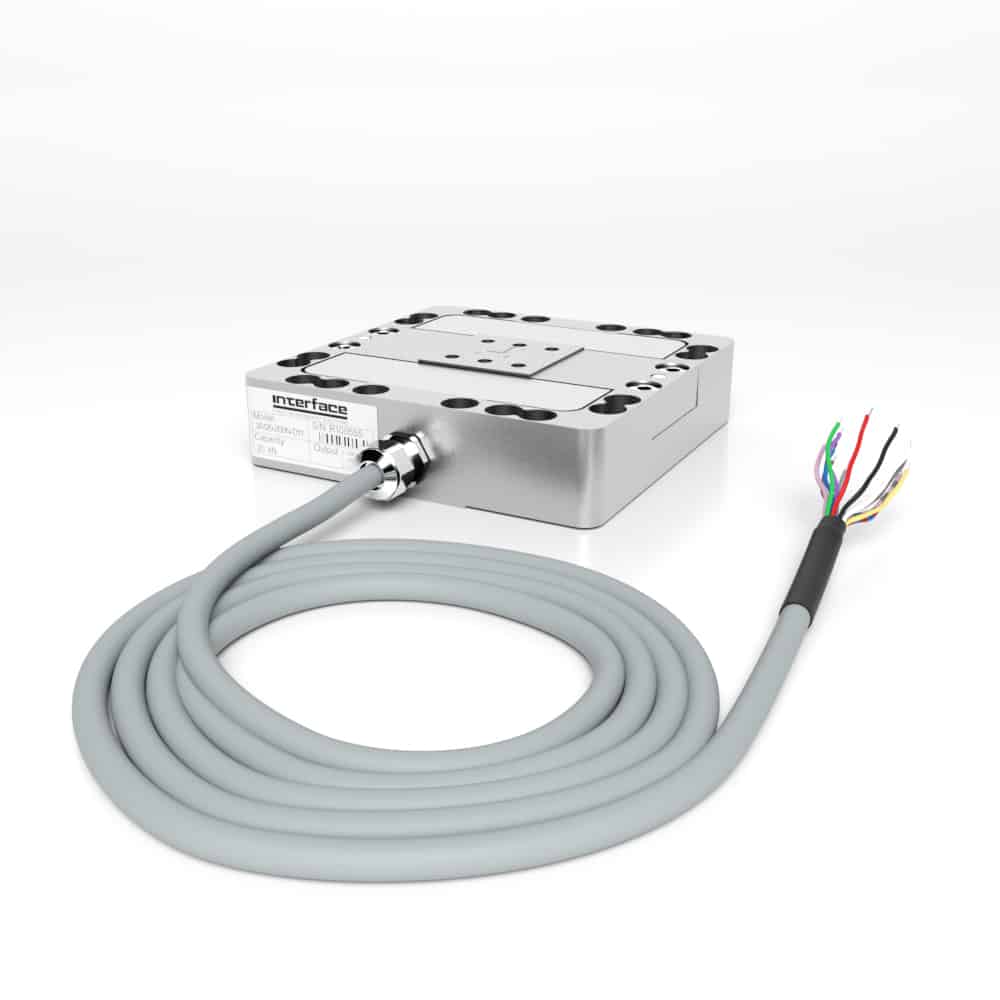
Robotic Incremental Sheet Forming (RISF) uses a multi-axis arm to progressively shape sheet metal without dedicated dies. To control dynamic tool pressures and prevent sheet tearing or tooling deflection, an Interface 6A40A 6-Axis Load Cell is mounted directly between the robot flange and forming tool. Connected to the BX8-HD44 Data Acquisition System and BlueDAQ software, the system feeds continuous force and moment data to the controller to dynamically regulate downforce and protect robot joints.
Robot Grinding and Polishing
Automated surface finishing requires consistent contact force across complex contours, compensating for part tolerances and abrasive disc wear. An Interface 6A40A 6-Axis Load Cell is installed at the end-of-arm tooling interface behind the grinding spindle, measuring real-time normal and tangential loads. Using the BX8-HD44 DAQ and BlueDAQ, the setup delivers low-latency feedback for active force compensation, eliminating part gouging and ensuring a uniform surface finish.
Cobot Safety Programming
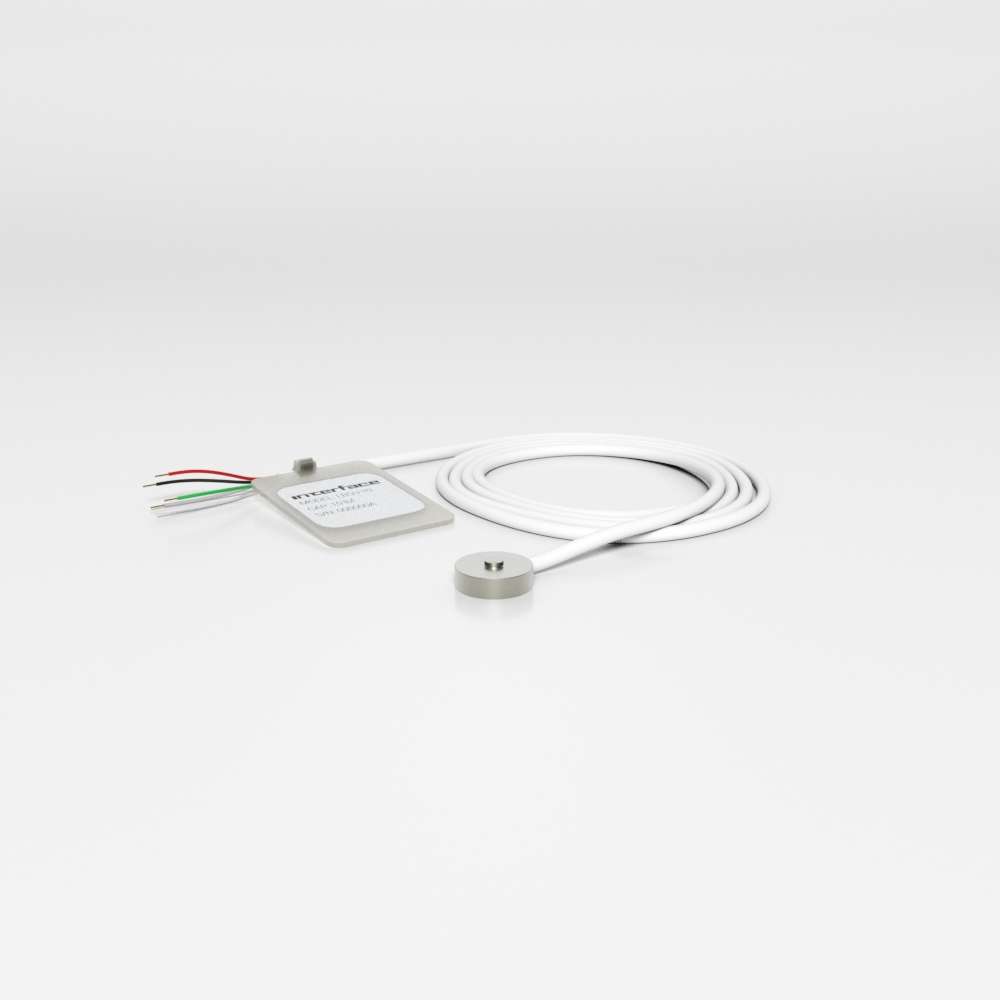
Collaborative workstations require deterministic physical feedback to enforce human-safe operation. A multi-point sensing architecture combines four Interface 3-Axis Load Cells arranged as a base reaction force plate with two ConvexBT Load Button Load Cells embedded inside the gripper jaws. If anomalous impact forces are detected at the base or grip thresholds are exceeded, the system triggers an immediate safety stop to prevent pinch and collision injuries.